Transport, robotics and navigation
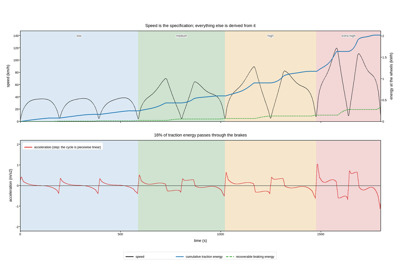
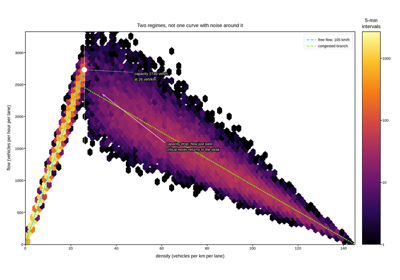
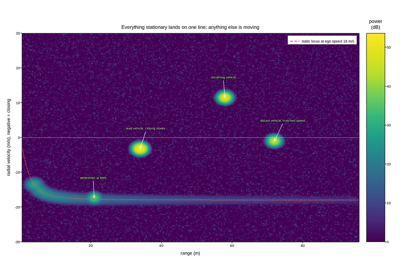
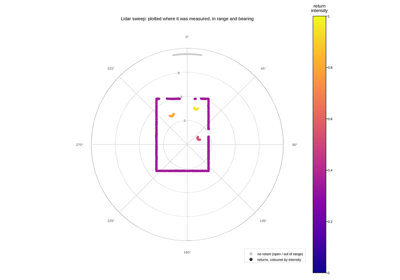
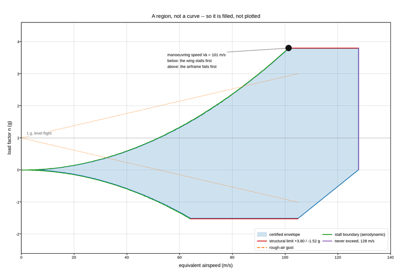
Drive cycles, traffic flow, automotive radar, lidar scans and flight envelopes. Vehicle data is where a plot’s native coordinate system most often is not Cartesian – a lidar returns range against bearing, a radar returns range against Doppler – and where an operating envelope rather than a curve is the thing being drawn.
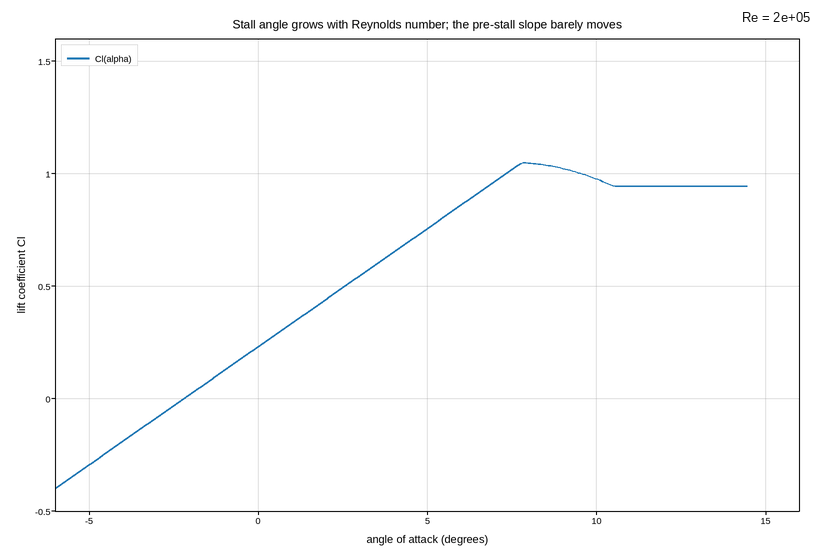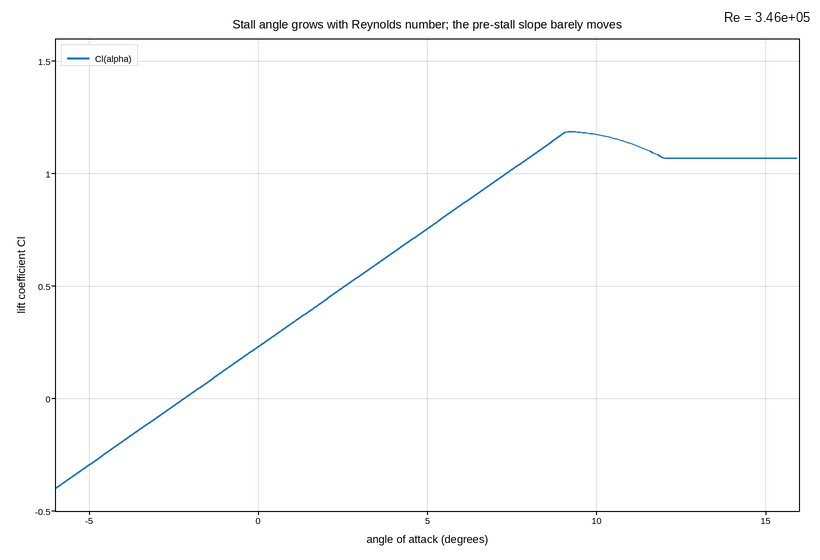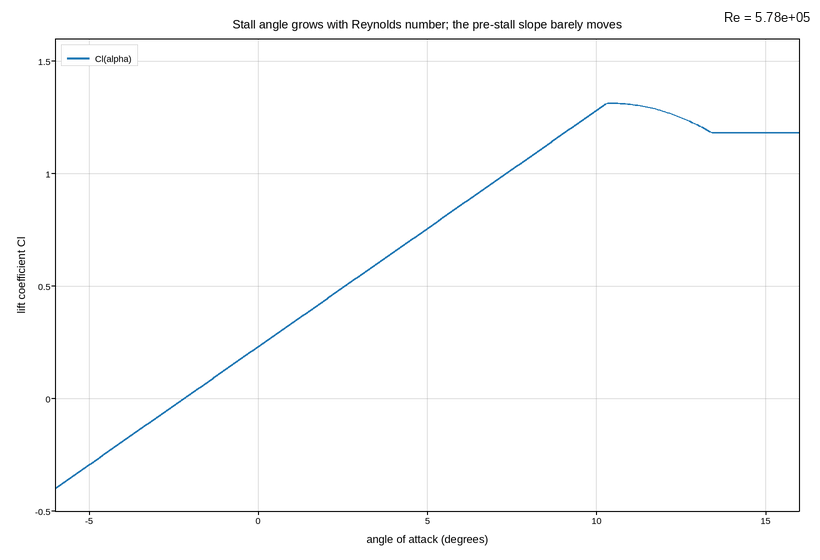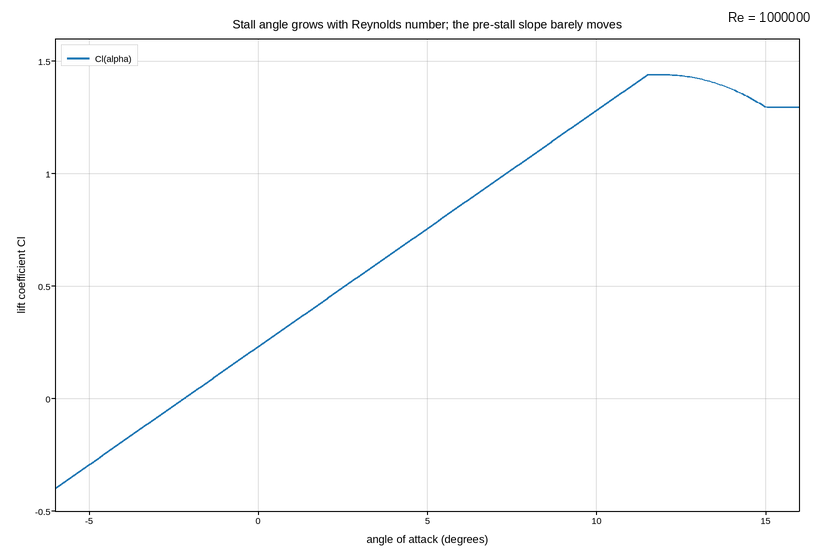
Stall creeping outward as Reynolds number climbs, animated
Stall creeping outward as Reynolds number climbs, animated